Cooperative multi-UAV platform for contested GNSS conditions, with resilient communications and edge processing.
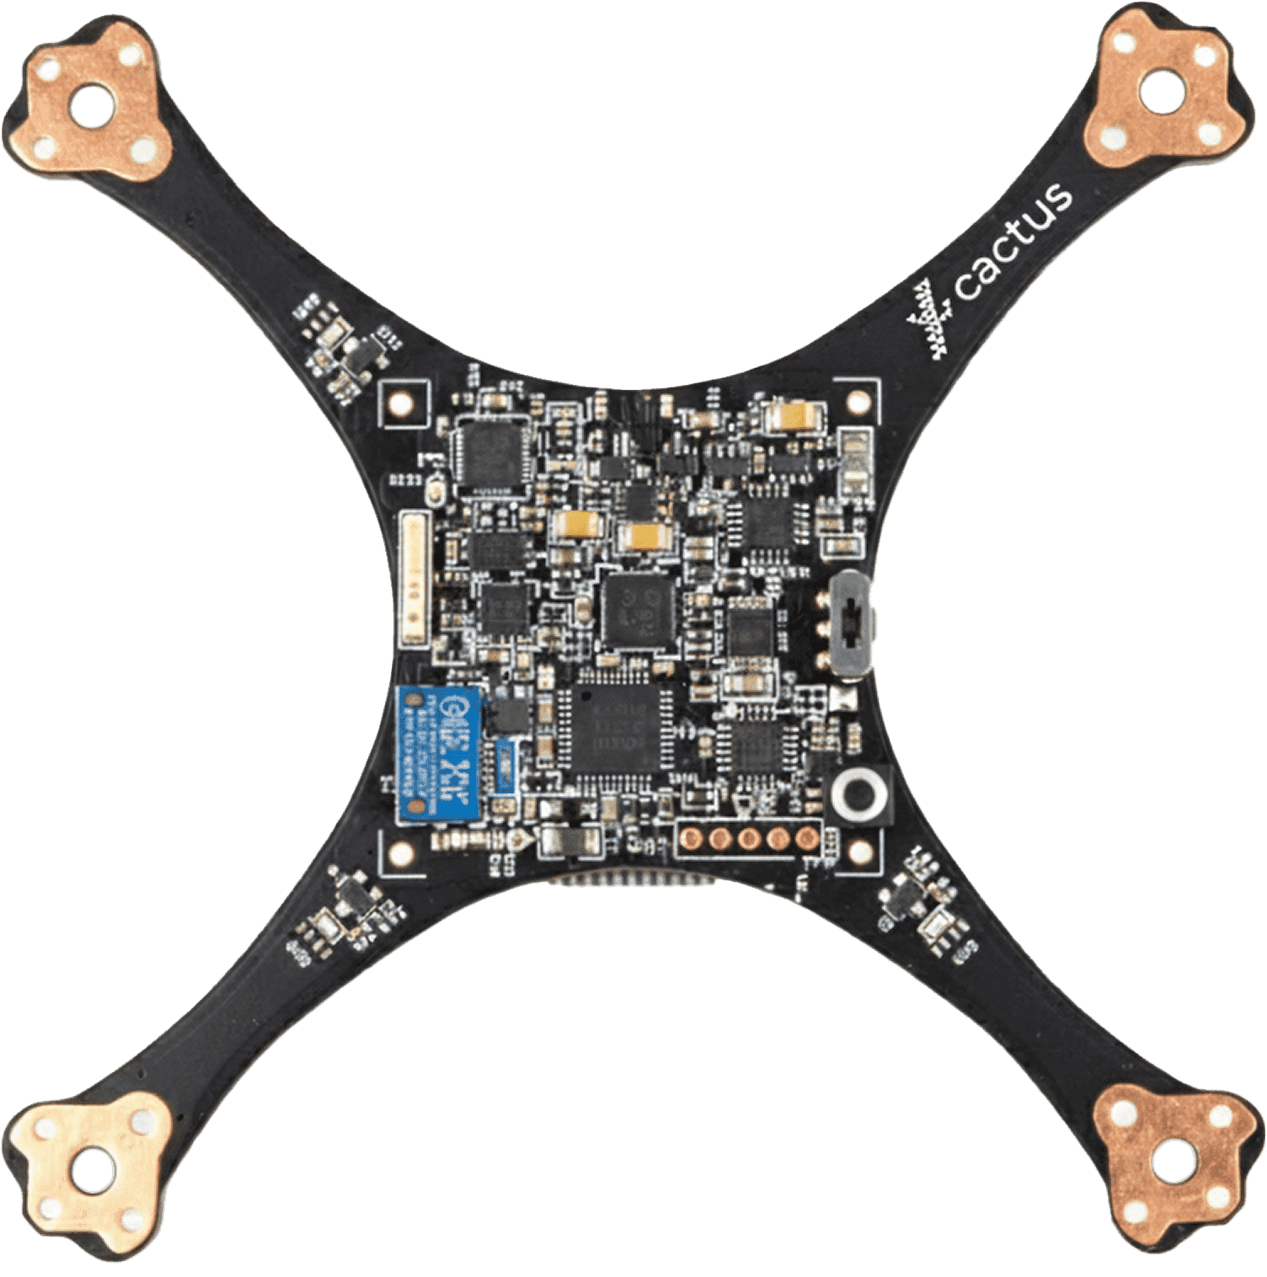

Critical infrastructure required several UAVs to cooperate while operating under degraded communications and GNSS jamming or spoofing. The system needed resilient communications, accurate positioning and onboard processing.

The platform combines embedded hardware, firmware and connectivity architecture with RTK, NTRIP, anti-jamming and anti-spoofing capabilities. Mesh networking provides a fallback communication path under degraded conditions, while edge processing supports cooperative multi-UAV.

Anti-jamming and anti-spoofing capabilities
Resilient mesh communications
RTK and NTRIP positioning
Cooperative multi-UAV architecture
Edge processing

Embedded control electronics

Communication integration

Remote monitoring

Mission firmware

System validation
Technologies:
Embedded systems, Firmware, RF communications, GNSS, Sensor integration, Drone electronics, MAVLink, Ignion, Machine Learning (Edge AI), RTK, NTRIP, mesh
Methodology:
Hardware & Firmware co-design, System integration, Field-oriented testing
Team:
3 engineers
Duration:
12 months